
2 VM Series Manual V2.0
Preface
Thank you for choosing WECON VM Series AC Drive.
This user manual introduces the technical specifications, installation instructions, functions and performance of VM Series AC Drive properly. Please read this user manual carefully before carrying out works such as installation, commissioning, maintenance, etc.
You are specially warned to read and understand safety precaution items of this manual before using this product, and to ensure that relevant electrical installation testers’ professional qualification shall be in line with the provisions of the labor supervision department, and the electrical and environmental conditions for product use shall be in conformity with relevant national standards.
Be sure to verify that the wiring is correct before powering on the product. Before starting the product, it is necessary to debug to ensure correct motor rotating direction.
Safety precautions
■ Warning sign
 DANGER: Indicates that failure to comply with the notice will result in severe personal injure or even death.
 WARNING: Indicates that failure to comply with the notice will result in moderate personal injury, property damage or equipment damage.
 WARNING |
|
 DANGER |
|
Product information
Technical specifications
| Input Frequency (Hz) | 0-50/60 Hz fluctuation range :±5% |
|---|---|
| Output Voltage | AC 0~Input Voltage |
| Output Frequency | 0~1000Hz |
| Control Mode | V/F Control |
| Overload Ability |
|
| Protection Level | IP20 |
| Altitude | Normal use below 1000m, derating 1% for every 100m rise above 1000m, up to 3000m |
| Ambient Temperature | -10℃~+50℃ (IF the ambient temperature is between 40°C and 50°C, please use with derating) |
| Humidity | <95%RH, no condensation |
| Shock | <5.9m/s²(0.6g) |
| Storage Temperature | -25℃~ 60℃ |
Table 2-1 Technical specifications
Nameplate
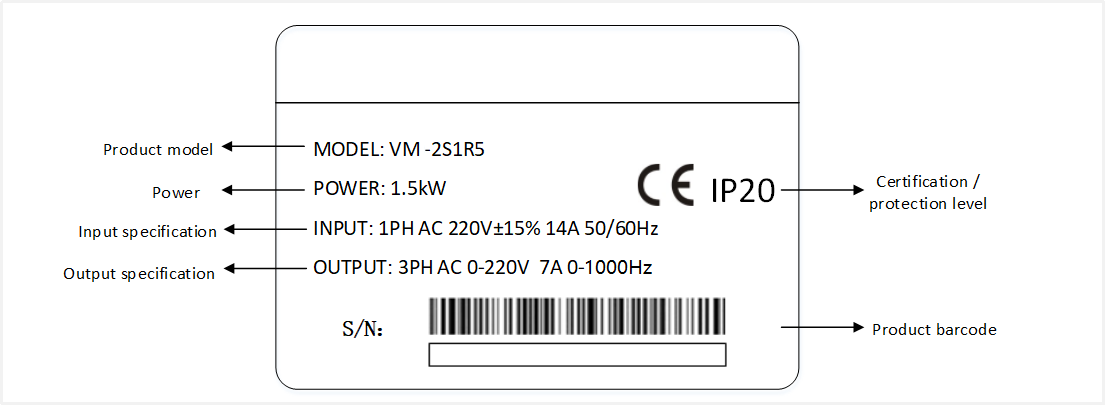
Figure 2-1 Product nameplate
Model description
VM – 2 S 1R5
① ② ③ ④
| Field | No. | Identification | Description |
|---|---|---|---|
| Product series | ① | Product series | VM series |
| Voltage grade | ② | Voltage grade |
|
| The input power | ③ | Power phase identification |
|
| Rated power | ④ | Power range | 1R5-1.5kW, R is the decimal point |
Table 2-2 VM series model
Product model
| Model | Rated Power(kW) | Input Voltage | Rated Output Current(A) |
|---|---|---|---|
| VM-2SR75 | 0.75 | Single Phase AC 220V±15% | 4 |
| VM-2S1R5 | 1.5 | 7 | |
| VM-2S2R2 | 2.2 | 9.6 | |
| VM-4TR75 | 0.75 | 3 Phase AC 380V±15% | 2.5 |
| VM-4T1R5 | 1.5 | 3.8 | |
| VM-4T2R2 | 2.2 | 5.1 | |
| VM-4T004 | 4 | 9 | |
| VM-4T5R5 | 5.5 | 13 | |
| VM-4T7R5 | 7.5 | 17 |
Table 2-3 Product model table
Installation
Overall structural drawing
(unit: mm)

Figure 3-1 Outline dimension diagram
| Model | Outer Dimension | Installation Dimension | Hole | |||
|---|---|---|---|---|---|---|
| H | W | D | H1 | W1 | d | |
| VM-2SR75 | 142 | 72 | 116 | 130 | 59 | 5 |
| VM-2S1R5 | ||||||
| VM-2S2R2 | ||||||
| VM-4TR75 | ||||||
| VM-4T1R5 | ||||||
| VM-4T2R2 | ||||||
| VM-4T004 | 196 | 95 | 132 | 179 | 79 | 5.5 |
| VM-4T5R5 | 225 | 115 | 154 | 208 | 99 | 5.5 |
| VM-4T7R5 | ||||||
Table 3-1 Outline dimension
Terminal connection

Figure 3-2 Terminal connection

Figure 3-3 Terminal connection
Main circuit connection
| Terminal | Name | Description |
|---|---|---|
| R/L、S、T/N | Input Power | Connected to input power |
| U、V、W | Output Power | Connected to motor |
 | Grounding | Connected to ground |
| 10V/GND | 10V Power | Maximum Current: 20mA |
| 24V/COM | 24V Power | Maximum Current: 150mA |
| AI/GND | Analog Input | DC 0V~10V or 0/4~20mA, set by parameter F5.41 |
| AO/GND | Analog Output | 0-10V |
DI1/DI2 DI3/DI4 | Digital Input | External digital signal input |
| RA/RB/RC | Relay Output | RA/RC NO,RA/RB NC AC 250V,10A; DC30V,10A |
| S+/S- | RS485 Communication |
|
| RJ45 Port | As shown in the figure above; pin 1 is connected to S+, and pin 2 is connected to S- |
Table 3-2 Main circuit terminals and function
Display and operation
Keypad
You can modify the parameters, monitor the working status and start or stop the AC Drive by operating the keypad, as shown in the following figure.

Figure 4-1 Keypad diagra
Keypad operation
| Item | Name | Function |
|---|---|---|
| Indicators | LED Indicators |
|
| Button | PRG | Enter or exit parameter setting |
| ENT | Enter the parameters step by step、save parameter adjustments | |
| △ | Increase parameter or its value | |
| ▽ | Decrease parameter or its value | |
| >> | During parameter setting, select the modification bit of the parameter During stop/run monitoring, the display parameters can be selected cyclically | |
| RUN/STOP | In keypad operation mode, control run and stop It can be used for error reset when the drive alarms | |
| Potentiometer | Speed Adjusting Potentiometer | Can be used for speed(frequency)adjusting |
Table 4-1 Description of Indicators and key
Parameter function
“○” indicates that the set value of this parameter can be changed when the VFD is in stop or running state.
“●” indicates that the set value of this parameter cannot be changed when the VFD is running.
“◎” indicates that the value of this parameter is the actual detection record value and cannot be changed.
Functional parameters
| Code | Name | Range | Default | Feature | RAM address | |
|---|---|---|---|---|---|---|
| F0.00 | Industrial marco |
| 0 | ● | 0000 | |
| F0.01 | Start/Stop channel |
| 0 | ● | 0001 | |
| F0.02 | UP/DOWN standard | Reserved | 1 | ● | 0002 | |
| F0.03 | Main Frequency Source X option |
| 1 | ● | 0003 | |
| F0.04 | Auxiliary Frequency Source Y option | Same as F0.03 | 0 | ● | 0004 | |
| F0.05 | Range of Auxiliary Frequency Source Y |
| 0 | ○ | 0005 | |
| F0.06 | Percentage Range of Auxiliary Frequency Source Y | 0% to 150% | 100% | ○ | 0006 | |
| F0.07 | Combination Option of F0.03 & F0.04 | LED Ones Place: Frequency Source Selection
LED Tens Place: Combination Operation
LED hundreds Place: Frequency Control direction selection | 0 | ○ | 0007 | |
| F0.08 | Keypad Setting Frequency | 0.00 to F0.12 | 50.00Hz | ○ | 0008 | |
| F0.09 | Running Direction |
| 0 | ○ | 0009 | |
| F0.10 | Maximum Output Frequency | 0.00 to 320.00Hz | 50.00Hz | ● | 000A | |
| F0.11 | Upper Limit Frequency Source |
| 0 | ● | 000B | |
| F0.12 | Maximum Running Frequency | F0.14 to F0.10 | 50.00Hz | ○ | 000C | |
| F0.13 | Reserved | Reserved | 0.00Hz | ○ | 000D | |
| F0.14 | Lower Limit Frequency | 0.00 to F0.12 | 0.00Hz | ○ | 000E | |
| F0.15 | The Function of Frequency Lower Limit |
| 1 | ○ | 000F | |
| F0.16 | Carrier Frequency:Detail | 0.6 to 15.0kHz | Due to VFD Model | ● | 0010 | |
| F0.17 | Carrier PWM wave characteristics selection | LED Ones Place: 0: Independent of temperature 1: Related to temperature, >75, 1.0 Khz LED Tens Place: 0: Independent of the output frequency 1: Related to the output frequency LED Hundreds Place: random PWM depth 0: Invalid 1-8: , adjust depth LED Thousands Place: over modulation option 0: Invalid 1: Valid | 1001 | ● | 0011 | |
| F0.18 | Acceleration Time 1 | 0.01 to 650.00s | Due to VFD Model | ○ | 0012 | |
| F0.19 | Deceleration Time 1 | 0.01 to 650.00s | Due to VFD Model | ○ | 0013 | |
| F0.20 | Default Setting Restoring |
| 0 | ● | 0014 | |
| F0.21 | Parameter Lock |
| 0 | ○ | 0015 | |
| F0.23 | Unit of Acceleration & Deceleration Time |
| 2 | ● | 0017 | |
| F0.24 | Acceleration And Deceleration Time Reference Frequency |
| 0 | ● | 0018 | |
| F0.25 | Fan Control Option | Ones Place : Run/Stop Option
| 01 | ○ | 0019 | |
| F0.26 | Frequency Command Decimal Point | 1:One Decimal Place 2:Two Decimal Place | 2 | ● | 001A | |
| F1.00 | Start Option | Ones Place: Start Option
Tens Place: Speed Tracking Direction
| 0 | ● | 0100 | |
| F1.01 | Reserved | 0 | ● | 0101 | ||
| F1.02 | Speed Tracking Period | 0.01 to 60.00s | 0.50s | ○ | 0102 | |
| F1.03 | Starting Frequency | 0.00 to 60.00Hz | 0.50Hz | ○ | 0103 | |
| F1.04 | Last Period of Starting Frequency | 0.0 to 50.0s | 0.0s | ● | 0104 | |
| F1.05 | Braking Current of Starting | 0.0 to 150.0% | 60.0% | ● | 0105 | |
| F1.06 | Braking Period before Starting | 0.0 to 60.0s | 1.0s | ● | 0106 | |
| F1.07 | Acceleration & Deceleration Curve |
| 00 | ● | 0107 | |
| F1.08 | S-Curve Starting Acceleration Speed | 20.0% to 100.0% | 50.0% | ● | 0108 | |
| F1.09 | S-Curve Starting Deceleration Speed | 20.0% to 100.0% | 50.0% | ● | 0109 | |
| F1.10 | Stopping Option |
| 0 | ○ | 010A | |
| F1.11 | DC Braking Beginning Frequency | 0.00 to 50.00Hz | 1.00Hz | ○ | 010B | |
| F1.12 | DC Braking Delay | 0.0 to 60.0s | 0.0s | ○ | 010D | |
| F1.13 | DC Braking Current | 0.0 to 150.0% | 60.0% | ○ | 010C | |
| F1.14 | DC Braking Period | 0.0 to 60.0s | 0.0s | ○ | 010E | |
| F1.15 | Stopping Frequency | 0.00 to 60.00Hz | 0.50Hz | ○ | 010F | |
| F1.16 | Zero Speed Holding Torque Valid Period | 0.0 to 6000.0sec When it is set to 6000.0s, it will be kept valid all the time | 0 | ● | 0110 | |
| F1.17 | Zero Speed Holding Torque | 0.0 to 150.0% | Due to VFD Model | ● | 0111 | |
| F2.00 | Type of Motor |
| 0 | ● | 0200 | |
| F2.01 | Motor Rated Power | 0.4 to 1000.0kW | Due to VFD Model | ● | 0201 | |
| F2.02 | Motor Rated Voltage | 0 to 1500V | Due to VFD Model | ● | 0202 | |
| F2.03 | Motor Rated Current | 0.1 to 2000.0A | Due to VFD Model | 0203 | ||
| F2.04 | Motor Rated Frequency | 0.01 to F0.10 | Due to VFD Model | ● | 0204 | |
| F2.05 | Motor Rated RPM | 0 to 65000rpm | Due to VFD Model | ● | 0205 | |
| F2.06 | Motor Stator Resistance | 0.001 to 65.000 | Due to VFD Model | ● | 0206 | |
| F2.07 | Motor Rotor Resistance | 0.001 to 65.000 | Due to VFD Model | ● | 0207 | |
| F2.08 | Motor Stator and Rotor Leakage Inductance | 0.1 to 6500.0mH | Due to VFD Model | ● | 0208 | |
| F2.09 | Motor Stator and Rotor Mutual Inductance | 0.1 to 6500.0mH | Due to VFD Model | ● | 0209 | |
| F2.10 | Motor No-load Current | 0.1 to 650.0A | Due to VFD Model | ● | 020A | |
| F2.11 | Motor Auto Tuning Option |
| 0 | ● | 020B | |
| F2.12 | G/P Model |
| 0 | ◎ | 020C | |
| F2.13 | Turn Ratio of Main and Auxiliary Coils of Single-Phase Asynchronous Motor | 10 - 200% | 80% | ● | 020D | |
| F2.14 | Single-Phase Motor Current Calibration Factor | 50 - 200% | 120% | ● | 020E | |
| F3.00 | ASR (Speed loop) proportional gain 1 | 0.00 to 1.00 | 0.20 | ○ | 0x0300 | |
| F3.01 | ASR (Velocity ring) integration time 1 | 0.01 to 10.00s | 0.10 | ○ | 0x0301 | |
| F3.02 | Loss of velocity protection value | 0 to 5000ms | 0ms | ○ | 0x0302 | |
| F3.03 | ASR filtering time 1 | 0.000 to 0.100s | 0.005s | ○ | 0x0303 | |
| F3.04 | ASR switching frequency 1 | 0.00 to 50.00Hz | 5.00Hz | ○ | 0x0304 | |
| F3.05 | ASR (Speed loop) proportional gain 2 | 0.00 to 1.00 | 0.20 | ○ | 0x0305 | |
| F3.06 | ASR (Velocity loop) integration time 2 | 0.01 to 10.00s | 0.10 | ○ | 0x0306 | |
| F3.07 | Reserve | 0x0307 | ||||
| F3.08 | ASR filtering time 2 | 0.000 to 0.100s | 0.005s | ○ | 0x0308 | |
| F3.09 | ASR switching frequency 2 | 0.00 to 50.00Hz | 10.00Hz | ○ | 0x0309 | |
| F3.10 | Slip compensation coefficient | 0 to 250% | 100% | ○ | 0x030A | |
| F3.11 | Maximum output torque | 0.0 to 250.0% | 150.0% | ○ | 0x030B | |
| F3.12 | Reserve | - | ○ | 0x030C | ||
| F3.13 | Reserve | - | ○ | 0x030D | ||
| F3.14 | Reserve | - | ○ | 0x030E | ||
| F3.15 | Reserve | - | ○ | 0x030F | ||
| F3.16 | Current loop D axis proportional gain | 0.1 to 10.0 | 1.0 | ○ | 0x0310 | |
| F3.17 | Current loop D axis integral gain | 0.1 to 10.0 | 1.0 | ○ | 0x0311 | |
| F3.18 | Current loop Q axis proportional gain | 0.1 to 10.0 | 1.0 | ○ | 0x0312 | |
| F3.19 | Current loop Q axis integral gain | 0.1 to 10.0 | 1.0 | ○ | 0x0313 | |
| F3.20 | D-axis feed-forward gain | 0.0 to 200.0% | 50.0% | ○ | 0x0314 | |
| F3.21 | Q-axis feed-forward gain | 0.0 to 200.0% | 50.0% | ○ | 0x0315 | |
| F3.22 | Optimize the current loop bandwidth | 0.0 to 99.99ms | 2.00ms | ○ | 0x0316 | |
| F3.23 | Current loop control word | bit0:Invalid 0:AM-ACR;1:PMACR bit1: 0:old csr;1:new csr bit2: 0: Enable prediction;1: Disable prediction; bit3:0:old week;1:new week bit4: AM current loop PI feedback enable | 0 | ○ | 0x0317 | |
| F3.24 | Weak magnetic control current upper limit | 0 to 200% | 80% | ○ | 0x0318 | |
| F3.25 | Weak magnetic control feed forward gain | 0 to 500% | 100% | ○ | 0x0319 | |
| F3.26 | Weak magnetic control proportional gain | 0 to 9999 | 500 | ○ | 0x031A | |
| F3.27 | Weak magnetic control integral gain | 0 to 9999 | 1000 | ○ | 0x031B | |
| F3.28 | MTPA gain | 0.0 to 500.0% | 0.0% | ○ | 0x031C | |
| F3.29 | MTPAl filtering time | 0.0 to 999.9ms | 100.0ms | ○ | 0x031D | |
| F3.30 | Magnetic flux compensation coefficient | 0 to 500% | 100% | ○ | 0x031E | |
| F3.31 | Open-loop vector observeration gain | 0 to 9999 | 1024 | 0x031F | ||
| F3.32 | Open-loop vector observation filtering time | 1 to 100ms | 10ms | 0x0320 | ||
| F3.33 | Open-loop vector compensation start frequency | 0 to 100.0% | 1.0% | 0x0321 | ||
| F3.34 | Open-loop vector control word | bit0: Invalid 0:AM-ACR; 1:PMACR bit1: 0:old csr;1:new csr bit2: 0:Enable prediction;1:Disable prediction; bit3:Emf compensation enable bit4: Emf compensation integral | 8 | 0x0322 | ||
| F3.35 | Synchronous open-loop starting mode | 0:Direct start; 1:Angle search start; | 1 | 0x0323 | ||
| F3.36 | Synchronous open-loop vector low-frequency boost | 0 to 100.0% | 50.0% | ○ | 0x0324 | |
| F3.37 | Synchronous open loop vector high-frequency boost | 0.0 to 100.0% | 5.0% | ○ | 0x0325 | |
| F3.38 | Low-frequency boost hold frequency | 0.0 to 100.0% | 10.00% | ○ | 0x0326 | |
| F3.39 | Low-frequency boost cutoff frequency | 0.0 to 100.0% | 20.00% | ○ | 0x0327 | |
| F3.40 | High-frequency injection voltage frequency | 0 to 2000Hz | 1000Hz | ○ | 0x0328 | |
| F3.41 | High-frequency injection voltage | 1 to 2000(4096 corresponding to the rated voltage of the motor) | 1000 | ○ | 0x0329 | |
| F3.42 | Phase-locked loop P | 0 to 500.00 | 50.00 | ● | 0x032A | |
| F3.43 | Phase-locked loop l | 0 to 500.00 | 40.00 | ○ | 0x032B | |
| F3.44 | High-frequency injection control word | bit0:Enable high-frequency injection bit1: Use high-frequency injection angle at low frequency bit2: High-frequency filter depth | 0/3 | ○ | 0x032C | |
| F4.00 | Linear VF Curve Selection |
| 0 | ● | 0400 | |
| F4.01 | Manual Torque Boost | 0.1 to 30.0%,0 = Auto Boost | Due to VFD Model | ○ | 0401 | |
| F4.02 | Torque Boost Cut-Off Frequency | 0.0 to 100.0% | 100.0% | ● | 0402 | |
| F4.03 | Customized VF Point 1 Frequency | 0.00 to F0.10 | 3.00Hz | ● | 0403 | |
| F4.04 | Customized VF Point 1 Voltage | 0.0 to 100.0% | 10.0% | ● | 0404 | |
| F4.05 | Customized VF Point 2 Frequency | 0.00 to F0.10 | 5.00Hz | ● | 0405 | |
| F4.06 | Customized VF Point 2 Voltage | 0.0 to 100.0% | 15.0% | ● | 0406 | |
| F4.07 | Customized VF Point 3 Frequency | 0.00 to F0.10 | 8.00Hz | ● | 0407 | |
| F4.08 | Customized VF Point 3 Voltage | 0.0 to 100.0% | 22.0% | ● | 0408 | |
| F4.09 | Customized VF Point 4 Frequency | 0.00 to F0.10 | 12.00Hz | ● | 0408 | |
| F4.10 | Customized VF Point 4 Voltage | 0.0 to 100.0% | 31.0% | ● | 040A | |
| F4.11 | Oscillation Suppression Gain | 0.0 to 10.0 | 5.0 | ○ | 041B | |
| F4.12 | Oscillation Suppression Filter Period | 1 to 1000ms | 50ms | ○ | 040C | |
| F4.16 | Auto Voltage Regular Function(AVR) |
| 0 | ○ | 0410 | |
| F5.00 | DI1 Function Option |
| 1 | ● | 0500 | |
| F5.01 | DI2 Function Option | 2 | ● | 0501 | ||
| F5.02 | DI3 Function Option | 9 | ● | 0502 | ||
| F5.03 | DI4 Function Option | 12 | ● | 0503 | ||
| F5.10 | VDI Function Option | 0 | ● | 050A | ||
| F5.15 | DI Terminal Filter Time | 0.000 to 60.000s | 0.010s | ○ | 050F | |
| F5.16 | Terminal Control Running Mode |
| 0 | ● | 0510 | |
| F5.17 | UP/DW Control Frequency Increase and Decrease Rate | 0.01 to 50.00Hz/s | 0.50Hz/s | ○ | 0511 | |
| F5.18 | AI1 Input Lower Limit | 0.00 to 10.00V | 0.00V | ○ | 0512 | |
| F5.19 | AI1 Input Lower Limit Relative Frequency Percentage | 0.00 to 100.00% | 0.00% | ○ | 0513 | |
| F5.20 | AI1 Input Upper Limit | 0.00 to 10.00V | 10.00V | ○ | 0514 | |
| F5.21 | AI1 Input Upper Limit Relative Frequency Percentage | 0.00 to 100.00% | 100.00% | ○ | 0515 | |
| F5.22 | AI1 Filter Time | 0.00-10.00sec | 0.10sec | ○ | 0516 | |
| F5.33 | DI1 Rising Edge Delay | 0.0 to 360.0s | 0 | ○ | 0521 | |
| F5.34 | DI2 Falling Edge Delay | 0.0 to 360.0s | 0 | ○ | 0522 | |
| F5.35 | DI2 Rising Edge Delay | 0.0 to 360.0s | 0 | ○ | 0523 | |
| F5.36 | DI2 Falling Edge Delay | 0.0 to 360.0s | 0 | ○ | 0524 | |
| F5.37 | DI1-DI4 Terminal Feature Option |
| 0000 | ● | 0525 | |
| F5.41 | Analog Input Signal Option | Ones Place: AI1 Tens Place: Reserved
| 000 | ● | 0529 | |
| F5.42 | Analog Input Curve Option | Ones Place: AI1 Tens Place: Reserved
| 000 | ● | 052A | |
| F5.60 | Terminal Operation Option | LED Ones Place: Recover Mode after Free Stop
LED Tens Place: Recover Mode after Emergent Stop
LED Hundreds Place: Working Mode after Error Reset
Thousands Place: Reserved | 0110 | ● | 050E | |
| F6.00 | Reserved | Reserved | 0 | ○ | 0600 | |
| F6.02 | Relay Output Option |
| 2 | ○ | 0602 | |
| F6.06 | Virtual VDO Output Option | 0 | ● | 0606 | ||
| F6.11 | Reserved |
| 0 | ○ | 060B | |
| F6.12 | AO1 Output Option | 0 | ○ | 060C | ||
| F6.13 | Reserved | 0 | ○ | 060D | ||
| F6.15 | A01 Output Signal Offset | -10.0 to 10.0% | 0.0% | ○ | 060F | |
| F6.16 | AO1 Output Signal Gain | 25.0 to 200.0% | 100.0% | ● | 0610 | |
| F6.20 | Relay 1 Output Delay | 0.0 to 360.0s | 0 | ○ | 0614 | |
| F6.22 | Reserved | Reserved | 0 | ○ | 0616 | |
| F6.24 | Relay 1 Off Delay | 0.0 to 360.0s | 0 | ○ | 0618 | |
| F6.27 | Relay output effective level | 0: Positive logic | 0 | ○ | 061B | |
| F6.28 | User Defined Output Option(EX)1 |
| 0 | ○ | 061C | |
| F6.29 | User Defined Comparison Option 1 | Ones Place: Comparison Option
Tens Place: Output Option
| 0 | ○ | 061D | |
| F6.30 | User Defined Dead Zone 1 | 0 to 65535 | 0 | ○ | 061E | |
| F6.31 | User Defined Output Option 1 Comparison 1 | 0 to 65535 | 0 | ○ | 061F | |
| F6.32 | User Defined Output Option 1 Comparison 2 | 0 to 65535 | 0 | ○ | 0620 | |
| F6.33 | User Defined Output Option(EX)2 | Same as F6.28 | 0 | ○ | 0621 | |
| F6.34 | User Defined Comparison Option 2 | Same as F6.29 | 0 | ○ | 0622 | |
| F6.35 | User Defined Dead Zone 2 | 0 to 65535 | 0 | ○ | 0623 | |
| F6.36 | User Defined Output Option 2 Comparison 1 | 0 to 65535 | 0 | ○ | 0624 | |
| F6.37 | User Defined Output Option 2 Comparison 2 | 0 to 65535 | 0 | ○ | 0625 | |
| F7.00 | Parameters Copy Option |
| 0 | ○ | 0700 | |
| F7.02 | Keypad Stop Button Priority Option | LED Ones Place: Priority at Terminal Control Mode (F0.01=1)
LED Tens Place: Priority at Communication Control Mode (F0.01=2)
LED Hundreds Place: Reserved LED Thousands Place: Reserved | 0 | ○ | 0702 | |
| F7.03 | Keypad Display Value 1(Running Status) | LED Ones Place: 1st Display Value
LED Tens Place: 2nd Display Value LED Hundreds Place: 3rd Display Value LED Thousands Place: 4th Display Value | 3420 | ○ | 0703 | |
| F7.04 | Keypad Display Value 2 (Running Status) | LED Ones Place: 1st Display Value
LED Tens Place: 2nd Display Value LED Hundreds Place: 3rd Display Value LED Thousands Place: 4th Display Value | 0 | ○ | 0704 | |
| F7.05 | Keypad Display Value 1 (Stop Status) | Same as F7.03 | 3421 | ○ | 0705 | |
| F7.06 | RPM Display Coefficient | 0.0 to 5000.0% | 100.0% | ○ | 0706 | |
| F7.07 | IGBT Temperature | 0 to 100 | - | ◎ | 0707 | |
| F7.08 | Rectifier Temperature | 0 to 100 | - | ◎ | 0708 | |
| F7.09 | Accumulated Running Time | 0 to 65535h | - | ◎ | 0709 | |
| F7.10 | Product Item Number | - | - | ◎ | 070A | |
| F7.11 | Software Version | - | - | ◎ | 070B | |
| F7.12 | Reserved | ○ | 070C | |||
| F7.13 | Accumulated Power-on Time | 0 to 65535h | - | ◎ | 070D | |
| F7.14 | Accumulated Power Consumption | - | ◎ | 070E | ||
| F8.00 | Set Frequency of Jog Run | 0.00 to F0.10 | 5.00Hz | ○ | 0800 | |
| F8.01 | Jog Run Acceleration Time | 0.01 to 650.00s | 10.00s | ○ | 0801 | |
| F8.02 | Jog Run Deceleration Time | 0.01 to 650.00s | 10.00s | ○ | 0802 | |
| F8.03 | Acceleration Time 2 | 0.01 to 650.00s | 10.00s | ○ | 0803 | |
| F8.04 | Deceleration Time 2 | 0.01 to 650.00s | 10.00s | ○ | 0804 | |
| F8.05 | Acceleration Time 3 | 0.01 to 650.00s | 10.00s | ○ | 0805 | |
| F8.06 | Deceleration Time 3 | 0.01 to 650.00s | 10.00s | ○ | 0806 | |
| F8.07 | Acceleration Time 4 | 0.01 to 650.00s | 10.00s | ○ | 0807 | |
| F8.08 | Deceleration Time 4 | 0.01 to 650.00s | 10.00s | ○ | 0808 | |
| F8.09 | Deceleration Time of Emergent Stop | 0.01 to 650.00s | 10.00s | ○ | 0809 | |
| F8.10 | Hopping Frequency Point | 0.00 to F0.10 | 0.00Hz | ○ | 080A | |
| F8.11 | Hopping Range | 0.00 to F0.10 | 0.00Hz | ○ | 080B | |
| F8.12 | Dead Zone Time for Forward and Reverse Switching | 0.0 to 120.0s | 0.0s | ○ | 080C | |
| F8.13 | Set Value of Running Period | 0 to 65000min | 0min | ○ | 080D | |
| F8.14 | Option for Set Value of Running Period |
| 0 | ○ | 080E | |
| F8.15 | Terminal Jog Run Priority |
| 1 | ○ | 080F | |
| F8.16 | PID Preset Switching Condition Option |
| 0 | ○ | 0810 | |
| F8.17 | PID Preset Switching Range | 0.0-100.0% | 3.0% | ○ | 0811 | |
| F9.00 | PID Set Value Source |
| 0 | ○ | 0900 | |
| F9.01 | PID Set Value | 0.00 to 100.0% | 50.0% | ○ | 0901 | |
| F9.02 | PID Feedback Value Source |
| 2 | ○ | 0902 | |
| F9.03 | PID Control Option | LED Ones Place: PID Control Feature
LED Tens Place: PID Control Option
LED Hundreds Place: Alignment selection 0: Non-center alignment Thousands Place: Reserved | 0100 | ○ | 0903 | |
| F9.04 | Feedback Signal Maximum Range | 0 to 100.0 | 100.0 | ○ | 0904 | |
| F9.05 | Proportional Gain (P) | 0.00 to 100.00 | 1.00 | ○ | 0905 | |
| F9.06 | Integration Time (I) | 0.00 to 10.00s | 0.10s | ○ | 0906 | |
| F9.07 | Differential Gain (D) | 0.00 to 10.00s | 0.00s | ○ | 0907 | |
| F9.08 | REV Cutoff Frequency | 0.0 to F0.10 | 0.00Hz | ○ | 0908 | |
| F9.09 | PID Control Deviation Limit | 0.0 to 100.0% | 0.0% | ○ | 0909 | |
| F9.10 | Differential Clipping | 0.00 to 100.00% | 0.10% | ○ | 090A | |
| F9.11 | Reserved | Reserved | 0.10s | ○ | 090B | |
| F9.12 | PID Feedback Filter Time | 0.00 to 100.00s | 0.00s | ○ | 090C | |
| F9.13 | PID Output Filter Time | 0.00 to 60.00s | 0.00s | ○ | 090D | |
| F9.14 | Proportional Gain (P2) | 0.00 to 100.00 | 1.00 | ○ | 090E | |
| F9.15 | Integration Time (I2) | 0.00 to 10.00s | 0.10s | ○ | 090F | |
| F9.16 | Differential Gain (D2) | 0.00 to 10.00s | 0.00s | ○ | 0910 | |
| F9.17 | PID Switching Condition |
| 0 | ○ | 0911 | |
| F9.18 | Switching Deviation 1 | 0.0 to F9.19 | 20.0% | ○ | 0912 | |
| F9.19 | Switching Deviation 2 | F9.18 to 100.0% | 80.0% | ○ | 0913 | |
| F9.20 | PID Preset Output | 0.0 to 100.0% | 100.0% | ○ | 0914 | |
| F9.21 | PID Preset Output Period | 0.0 to 6500.0s | 0.0s | ○ | 0915 | |
| F9.22 | Positive Maximum Value of Twice Output Deviation | 0.00 to 100.00% | 1.00% | ○ | 0916 | |
| F9.23 | Negative Maximum Value of Twice Output Deviation | 0.00 to 100.00% | 1.00% | ○ | 0917 | |
| F9.24 | Integral Property | Ones Place: Integral separation
Tens Place: When the output reaches the limit value, whether to stop the integration
| 0 | ○ | 0918 | |
| F9.25 | Feedback Offline Alarm Point | 0.0 to 100.0% | 0.0% | ○ | 0919 | |
| F9.26 | Feedback Offline Alarm Delay | 0.0 to 120.0s | 1.0s | ○ | 091A | |
| F9.27 | Feedback Offline Alarm Option |
| 0 | ○ | 091B | |
| F9.28 | PID Option |
| 0 | ○ | 091C | |
| F9.29 | Sleep Threshold | 0.0% to 100.0% | 60.0% | ○ | 091D | |
| F9.30 | Sleep Delay | 0.0 to 3600.0s | 3.0s | ○ | 091E | |
| F9.31 | Wakeup Threshold | 0.0% to 100.0% | 20.0% | ○ | 091F | |
| F9.32 | Wakeup Delay | 0.0 to 3600.0s | 3.0s | ○ | 0920 | |
| F9.33 | Minimum Output |
| 0 | ● | 0921 | |
| FA.00 | Motor Overload Protection Option |
| 1 | ○ | 0A00 | |
| FA.01 | Motor Overload Protection Level | 0.0 to 250.0% | 100.0% | ○ | 0A01 | |
| FA.02 | Motor Overload Warning Level
| 20.0 to 250.0% | Reserved | ○ | 0A02 | |
| FA.03 | Frequency Limit | 0.00Hz - 99.99Hz | 0.00Hz | ○ | 0A03 | |
| FA.04 | Overvoltage Stall Protection Gain | 0~500% | 100% | ○ | 0A04 | |
| FA.05 | Overvoltage Stall Protection Point | 110%~150% * Motor Rated Voltage | 135% | ○ | 0A05 | |
| FA.06 | Overvoltage Stall Protection Filter Time | 1~1000ms | 5ms | ○ | 0A06 | |
| FA.07 | Overcurrent Stall Protection Gain | 0 ~ 500% | 20% | ○ | 0A07 | |
| FA.08 | Overcurrent Stall Protection Point | 100%~200% * VFD Rated Current | 150% | ○ | 0A08 | |
| FA.09 | Overcurrent Stall Protection Filter Time | 1~1000ms | 20ms | ○ | 0A09 | |
| FA.10 | Short-circuit to Ground Protection Option |
| 0 | ○ | 0A0A | |
| FA.11 | AC Input Phase Loss Protection Option |
| 1 | ○ | 0A0B | |
| FA.12 | AC Output Phase Loss Protection Option |
| 1 | ○ | 0A0C | |
| FA.13 | Phase Loss Software Detection Point | 0.0 to 999.9% | 15.0% | ○ | 0A0D | |
| FA.14 | PWM parameter | Ones Place: PWM mode selection
Tens Place: Enable Voltage Prediction Compensation Hundreds Place: 0: SSSU Thousands Place: Random Carrier mode 0:Random Carrier 1:Random 0 Vector | 0110 | ● | 0A0E | |
| FA.15 | Hardware Current & Voltage Protection Option | Ones Place: Hardware Overcurrent Protection
Tens Place: Hardware Overvoltage Protection
Hundreds Place: SC Filtering Time Thousands Place: Reserved | 1110 | ○ | 0A0F | |
| FA.16 | Hardware Overcurrent Protection Point | 100 to 220% * VFD Rated Current | 180% | ○ | 0A10 | |
| FA.17 | Hardware Overcurrent Protection Delay | 1 to 5000ms | 500ms | ○ | 0A11 | |
| FA.18 | Protection Point of Too Low Bus Voltage | 40.0% to 100.0% | 100% | ○ | 0A12 | |
| FA.19 | Protection Point of Overvoltage | 120.0 ~ 200.0% | 100% | ○ | 0A13 | |
| FA.20 | Auto Error Reset Times | 0 to 5 | 0 | ○ | 0A14 | |
| FA.21 | Auto Error Reset Interval | 0.1 to 100.0s | 1.0s | ○ | 0A15 | |
| FA.23 | Flux Brake Gain | 0~500% | 170% | ○ | 0A16 | |
| FA.26 | Output power Correction Factor | 0~1000% | 100% | ○ | 0A1A | |
| FA.27 | Output Power Display Unit |
| 0 | ○ | 0A1B | |
| FA.28 | Speed Tracking Current Gain | 0 to 100.00% | 10% | ○ | 0A1C | |
| FA.29 | Speed tracking gain | 0 to 100.00% | 5% | ○ | 0A1D | |
| FA.30 | Speed tracking current | 10~ 200% | 60% | ○ | 0A1E | |
| FA.31 | Software Current Protection Option |
| 1 | ○ | 0A1F | |
| FA.32 | Software Current Protection Point | 200%-300% * VFD Rated Current | 270% | ○ | 0A20 | |
| FC.00 | RS485(Modbus)Communication Address | 1 to 247 | 1 | ○ | 0C00 | |
| FC.01 | Communication Baud Rate |
| 3 | ○ | 0C01 | |
| FC.02 | Modbus Data Format |
| 0 | ○ | 0C02 | |
| FC.03 | Modbus Communication Reply Delay | 0 to 500ms | 1ms | ○ | 0C03 | |
| FC.04 | Modbus Communication Timeout Alarm Delay | 0.1 to 100.0s | 1.0s | ○ | 0C04 | |
| FD.00 | INNER PLC(AND MULTI-STAGE SPEED)0 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D00 | |
| FD.01 | INNER PLC(AND MULTI-STAGE SPEED)1 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D01 | |
| FD.02 | INNER PLC(AND MULTI-STAGE SPEED)2 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D02 | |
| FD.03 | INNER PLC(AND MULTI-STAGE SPEED)3 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D03 | |
| FD.04 | INNER PLC(AND MULTI-STAGE SPEED)4 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D04 | |
| FD.05 | INNER PLC(AND MULTI-STAGE SPEED)5 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D05 | |
| FD.06 | INNER PLC(AND MULTI-STAGE SPEED)6 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D06 | |
| FD.07 | INNER PLC(AND MULTI-STAGE SPEED)7 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D07 | |
| FD.08 | INNER PLC(AND MULTI-STAGE SPEED)8 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D08 | |
| FD.09 | INNER PLC(AND MULTI-STAGE SPEED)9 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D09 | |
| FD.10 | INNER PLC(AND MULTI-STAGE SPEED)10 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D0A | |
| FD.11 | INNER PLC(AND MULTI-STAGE SPEED)11 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D0B | |
| FD.12 | INNER PLC(AND MULTI-STAGE SPEED)12 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D0C | |
| FD.13 | INNER PLC(AND MULTI-STAGE SPEED)13 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D0D | |
| FD.14 | INNER PLC(AND MULTI-STAGE SPEED)14 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D0E | |
| FD.15 | INNER PLC(AND MULTI-STAGE SPEED)15 | 0.0 to 100.0% * F0.10 | 0 | ○ | 0D0F | |
| FD.16 | Inner PLC Running Mode |
| 0 | ○ | 0D10 | |
| FD.17 | Inner PLC Power-off Memory Option |
| 0 | ○ | 0D11 | |
| FD.18 | Inner PLC Stage 0 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D12 | |
| FD.19 | Inner PLC Stage 0 Direction & Acceleration & Deceleration Time | LED Ones Place: Direction of the Stage
LED Tens Place: Acceleration & Deceleration Time
LED Hundreds Place: Reserved LED Thousands Place: Reserved | 0 | ○ | 0D13 | |
| FD.20 | Inner PLC Stage 1 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D14 | |
| FD.21 | Inner PLC Stage 1 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D15 | |
| FD.22 | Inner PLC Stage 2 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D16 | |
| FD.23 | Inner PLC Stage 2 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D17 | |
| FD.24 | Inner PLC Stage 3 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D18 | |
| FD.25 | Inner PLC Stage 3 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D19 | |
| FD.26 | Inner PLC Stage 4 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D1A | |
| FD.27 | Inner PLC Stage 4 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D1B | |
| FD.28 | Inner PLC Stage 5 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D1C | |
| FD.29 | Inner PLC Stage 5 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D1D | |
| FD.30 | Inner PLC Stage 6 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D1E | |
| FD.31 | Inner PLC Stage 6 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D1F | |
| FD.32 | Inner PLC Stage 7 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D20 | |
| FD.33 | Inner PLC Stage 7 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D21 | |
| FD.34 | Inner PLC Stage 8 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D22 | |
| FD.35 | Inner PLC Stage 8 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D23 | |
| FD.36 | Inner PLC Stage 9 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D24 | |
| FD.37 | Inner PLC Stage 9 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D25 | |
| FD.38 | Inner PLC Stage 10 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D26 | |
| FD.39 | Inner PLC Stage 10 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D27 | |
| FD.40 | Inner PLC Stage 11 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D28 | |
| FD.41 | Inner PLC Stage 11 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D29 | |
| FD.42 | Inner PLC Stage 12 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D2A | |
| FD.43 | Inner PLC Stage 12 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D2B | |
| FD.44 | Inner PLC Stage 13 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D2C | |
| FD.45 | Inner PLC Stage 13 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D2D | |
| FD.46 | Inner PLC Stage 14 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D2E | |
| FD.47 | Inner PLC Stage 14 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D2F | |
| FD.48 | Inner PLC Stage 15 Running Period | 0.0 to 6500.0(s/m/h) | 10.0 | ○ | 0D30 | |
| FD.49 | Inner PLC Stage 15 Direction & Acceleration & Deceleration Time | Same as FD.19 | 0 | ○ | 0D31 | |
| FD.50 | Inner PLC Running Option | LED Tens Place : Time Unit
LED Thousands Place: Starting Option
| 0 | ○ | 0D32 | |
| FD.51 | Multi-Stage Speed 0 Source |
| 0 | ○ | 0D33 | |
| FD.52 | Multi-Stage Speed Priority |
| 1 | ○ | 0D34 | |
| FE.00 | Lock Option of Parameters and Buttons |
| 0 | ○ | 0E00 | |
| FE.01 | User Password | 0 to 9999 | 0 | ○ | 0E01 | |
Table 5-1 Functional parameter
Monitoring parameters
| Parameter | Name | Minimum Unit | Priority | Address |
|---|---|---|---|---|
| D0.00 | Running Frequency(Hz) | 0.01Hz | ◎ | D000 |
| D0.01 | Set Frequency(Hz) | 0.01Hz | ◎ | D001 |
| D0.02 | Bus Voltage(V) | 0.1V | ◎ | D002 |
| D0.03 | Output Voltage(V) | 1V | ◎ | D003 |
| D0.04 | Output Current(A) | 0.01A | ◎ | D004 |
| D0.05 | Output power (kW) | 0.1kW | ◎ | D005 |
| D0.06 | Output torque (%) | 0.1% | ◎ | D006 |
| D0.07 | DI Input Status | 1 | ◎ | D007 |
| D0.08 | DO Output Status | 1 | ◎ | D008 |
| D0.09 | AI Voltage(V) | 0.01V | ◎ | D009 |
| D0.10 | Reserved | - | ◎ | D00A |
| D0.11 | Reserved | - | ◎ | D00B |
| D0.12 | IGBT Module Temperature(℃) | 0.1℃ | ◎ | D00C |
| D0.13 | Count value | 1 | ◎ | D00D |
| D0.14 | Load speed display | 1 | ◎ | D00E |
| D0.15 | PID Set | 1 | ◎ | D00F |
| D0.16 | PID FeedBback | 1 | ◎ | D010 |
| D0.17 | PLC Stage | 1 | ◎ | D011 |
| D0.18 | Reserved | - | ◎ | D012 |
| D0.19 | Feedback Speed(Unit0.1Hz) | 0.1Hz | ◎ | D013 |
| D0.20 | Reserved | - | ◎ | D014 |
| D0.21 | Feedback Speed(Unit0.1Hz) | 0.1Hz | ◎ | D015 |
| D0.22 | Reserved | - | ◎ | D016 |
| D0.23 | Reserved | - | ◎ | D017 |
| D0.24 | Reserved | - | ◎ | D018 |
| D0.25 | Current power-on time | 1Min | ◎ | D019 |
| D0.26 | Current running time | 0.1Min | ◎ | D01A |
| D0.27 | Reserved | - | ◎ | D01B |
| D0.28 | Communication setting | 0.01% | ◎ | D01C |
| D0.29 | Reserved | - | ◎ | D01D |
| D0.30 | Main frequency X display | 0.01Hz | ◎ | D01E |
| D0.31 | Auxiliary frequency Y display | 0.01Hz | ◎ | D01F |
Table 5-2 Monitoring Parameters
Fault recording parameters
| Function Code | Parameter Name | Setting Range | Property | Address |
|---|---|---|---|---|
| E0 GROUP THE LATEST FAULT RECORDS | ||||
| E0.00 | The latest fault type | No fault Overcurrent during acceleration (Err02) Overcurrent during deceleration (Err03) Overcurrent at constant speed (Err04) Overvoltage during acceleration (Err05) Overvoltage during deceleration (Err06) Overvoltage at constant speed (Err07) Undervoltage (Err09) AC Drive overload (Err10) Motor overload (Err11) Module overheating (Err14) External equipment fault (Err15) Data overflow (Err21) Running time arrival (Err26) (Err31)
| ◎ | E000 |
| E0.01 | Frequency by the latest failure | 0.0Hz~F0.10(Maximum frequency) | ◎ | E001 |
| E0.02 | Current by the latest failure | 0.00~655.35 | ◎ | E002 |
| E0.03 | Bus voltage by the latest failure | 0.0~810.0 | ◎ | E003 |
| E0.04 | Input terminal status by the lastest failure | 0-15 | ◎ | E004 |
| E0.05 | The temperature of AC Drive by the latest failure | 0~65535 | ◎ | E005 |
| E0.06 | The temperature of IGBT Module by the latest failure | 0~100℃ | ◎ | E006 |
| E0.07 | Inverter Fault Status | LED Ones Place: Running Direction
LED Tens Place: Running status
LED Hundreds Place: Reserved Thousands Place: Reserved | ◎ | E007 |
| E0.08 | Time of latest failure (timing from this on-power time) | 0~65535H | ◎ | E008 |
| E0.09 | Time of the latest failure (timing from the running beginning) | 0~65535H | ◎ | E009 |
| E0.10 | Fault Output Voltage | 0~1500V | ◎ | E00A |
| E0.11 | Reserved | - | ◎ | E00B |
| E1 ~ EE GROUP THE LAST 14 FAULT RECORDS | ||||
Main error codes and solutions
| Code | Description | Possible Causes | Solutions |
|---|---|---|---|
| ERR02 | Overcurrent during acceleration | There is grounding or short circuit in the output circuit of the controller | Eliminate peripheral faults and check whether there is a short circuit at the motor end |
| Acceleration time is set too short | Increase acceleration time | ||
| The controller model is selected improperly(with too small power) | Select the controller that matches the motor power and load conditions | ||
| ERR03 | Overcurrent during deceleration | There is grounding or short circuit in the output circuit of the controller | Eliminate peripheral faults and check whether there is a short circuit at the motor end |
| Deceleration time is set too short | Increase deceleration time | ||
| ERR04 | Overcurrent at constant speed | There is grounding or short circuit in the output circuit of the controller | Eliminate peripheral faults and check whether there is a short circuit at the motor end |
| Controller model is too small | Select the controller that matches the motor power and load conditions | ||
| ERR05 | Overvoltage during acceleration | Input voltage is too high | Adjust input voltage to a proper range |
| Acceleration time is set too short | Increase acceleration time | ||
| No braking unit and braking resistor installed | Install braking unit and braking resistor | ||
| ERR06 | Overvoltage during deceleration | Input voltage is too high | Adjust input voltage to a proper range |
| Deceleration time is set too short | Increase deceleration time | ||
| No braking unit and braking resistor installed | Install braking unit and braking resistor | ||
| ERR07 | Overvoltage at constant speed | Input voltage is too high | Adjust input voltage to a proper range |
| ERR08 | Snubber resistor overload | The input voltage is not within the specified range | Adjust input voltage to a proper range |
| ERR09 | Low input voltage | The input voltage is not within the specified range | Adjust input voltage to a proper range |
| Abnormal bus voltage detection; abnormality of rectifier bridge, snubber resistor, drive board and control board | Seek for technical support | ||
| ERR10 | VFD overload | Load is too large or motor is stuck | Reduce load and check motor and mechanical condition |
| Controller model is too small | Select the controller that matches the motor power and load conditions | ||
| ERR11 | Motor overload | The motor overload protection parameters (FA.01-FA.02) are not properly set | Correctly set them |
| Load is too large or motor is stuck | Reduce load and check motor and mechanical condition | ||
| ERR12 | Input phase loss | Abnormal three-phase input power | Check and troubleshoot existing problems in peripheral circuits |
| Failure of drive board or control board | Seek for technical support | ||
| ERR13 | Output phase loss | Motor failure | Check if the motor winding is open |
| The wirings between controller and motor is abnormal | Troubleshoot peripherals | ||
| When the motor is running, the three-phase output of the controller is unbalanced | Check whether the three-phase windings of the motor are normal and troubleshoot | ||
| Failure of IGBT or drive board | Seek for technical support | ||
| ERR14 | IGBT overheat | Ambient temperature is too high | Lower ambient temperature |
| Air duct blocked | Clear air duct | ||
| Fan failure | Replace the fan | ||
| Failure of thermistor or IGBT | Seek for technical support | ||
| ERR15 | External alarm input | Input external fault signal through DI terminal | Clear external fault signal |
| ERR18 | Current detection failure | Abnormal current detection circuit | Seek for technical support |
| Control board failure | Seek for technical support | ||
| ERR21 | Parameter R/W failure | Control board failure | Seek for technical support |
| ERR22 | EEPROM failure | EEPROM chip failure | Seek for technical support |
Table 5-3 Main Error Codes and Solutions
Communication protocol
VM Series AC Drive provides RS485 communication interface and supports Modbus communication protocol. Users can achieve centralized control by computer or PLC, set AC Drive operation commands, modify or read function code parameters, read the working state and fault info of the AC Drive.
Communication Address Description
The communication address listed in the function code table is in the way of writing to RAM, and the data will not be saved after the VFD is powered off. During communication, for the write command "06H", if the parameters need to be stored in power-down, the way of writing to EEPROM should be used, and the original The "0" of the highest bit of the RAM address is changed to "F", and converted into the corresponding EEPROM address, such as: "0XXX" to "FXXX", address conversion example:
The upper limit frequency is F012, the communication address for writing RAM is: 000C, and the address corresponding to EEPROM is: F00C.
Acceleration time F018, the communication address for writing RAM is: 0012, and the address corresponding to EEPROM is: F012.
It should be noted that the erasing life of EEPROM is about 1 million times. After the erasing times are exceeded, the reliability of data storage will be affected. If it is not necessary, it is recommended to use the method of writing RAM to control communication.
RS485 communication registers
| Name | Address | Description | Data Remarks | Feature |
|---|---|---|---|---|
| Set Frequency | 1000H | -10000 to 10000 | ±100.00% * F0.10 | R/W |
| Control Command | 2000H | 0001: FWD Running | - | written only |
| 0002: REV Running | - | written only | ||
| 0003: FWD JOG | - | written only | ||
| 0004: REV JOG | - | written only | ||
| 0005: Free Stop(Coast to Stop) | - | written only | ||
| 0006: Deceleration Stop | - | written only | ||
| 0007: Error Reset | - | written only | ||
| Running Status | 3000H | 0001: FWD Running | - | read only |
| 0002: REV Running | - | read only | ||
| 0003: Stopped | - | read only | ||
| Monitoring Data | 1001H | Running Frequency(Hz) | 2 decimal places | read only |
| 1002H | Set Frequency(Hz) | 2 decimal places | read only | |
| 1003H | Bus Voltage(V) | 1 decimal places | read only | |
| 1004H | Output Voltage(V) | 1 decimal places | read only | |
| 1005H | Output Current(A) | 2 decimal places | read only | |
| 100DH | IGBT Temperature | 1 decimal places | read only | |
| 1008H | DI Input Status | DI1-DI4 Add up by binary bit weight | read only | |
| 100CH | Keypad Potentiometer Voltage(V) | 1 decimal places | read only | |
| 100AH | AI Input Voltage(V) | 1 decimal places | read only | |
| 100FH | Motor RPM | 1 decimal places | read only | |
| 1012H | PLC Stage | 0-15 | read only | |
| Error Record | 8000H | 0000: No Error | - | read only |
| 0002: Overcurrent during acceleration | - | read only | ||
| 0003: Overcurrent during deceleration | - | read only | ||
| 0004: Overcurrent at constant speed | - | read only | ||
| 0005: Overvoltage during acceleration | - | read only | ||
| 0006: Overvoltage during deceleration | - | read only | ||
| 0007: Overvoltage at constant speed | - | read only | ||
| 0009: Low input voltage | - | read only | ||
| 000A: VFD overload | - | read only | ||
| 000B: Motor overload | - | read only | ||
| 000D: Output phase loss | - | read only | ||
| 000E: IGBT overheat | - | read only | ||
| 000F: External alarm input | - | read only | ||
| 0012: Current detection failure | - | read only | ||
| 0015: Parameter R/W failure | - | read only | ||
| Communication Failure Record | 8001H | 0000: No Error | - | read only |
| 0001: Command code error | - | read only | ||
| 0002: Communication transmission error | - | read only | ||
| 0003: CRC Check error | - | read only | ||
| 0004: Invalid Address | - | read only | ||
| 0005: Invalid Data | - | read only | ||
| 0006: Invalid parameter setting | - | read only | ||
| 0007: System Locked | - | read only | ||
| 0008: Parameter setting | - | read only |
Table 6-1 Control Command Addresses